
브러시리스 드라이버 매개변수 조정 규칙의 탐색 및 분석
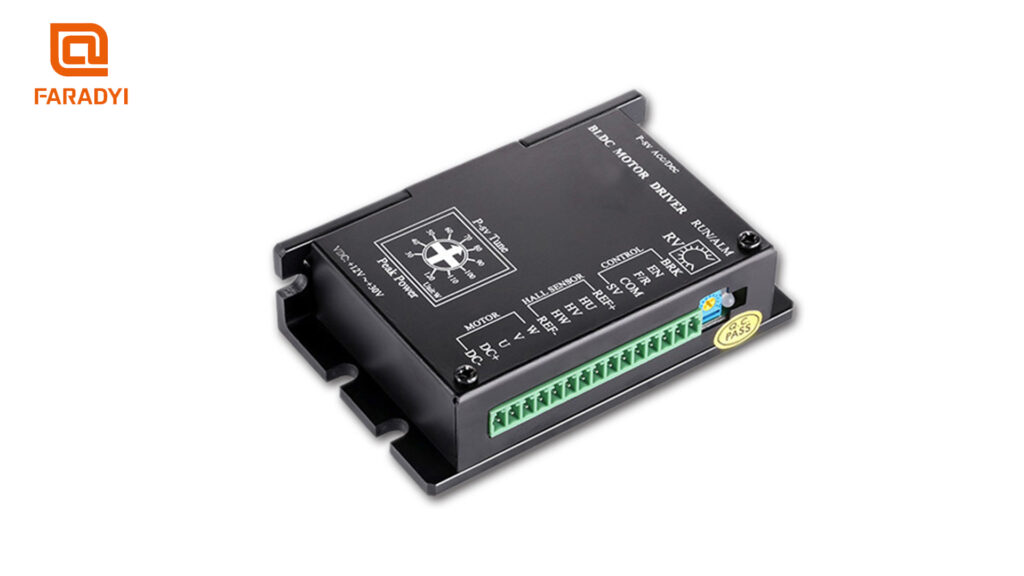
This article discusses how to adapt PID parameters to the dynamic process of brushless driver systems. It covers adjusting Kp and Ki values based on the deviation magnitude, deviation rate, and controlled quantity’s proximity to the set value. It also highlights the importance of differential action in improving system dynamics and control accuracy. Understanding these rules can help optimize the performance of brushless driver systems.