
How to Choose a Stepper Motor Use Environment
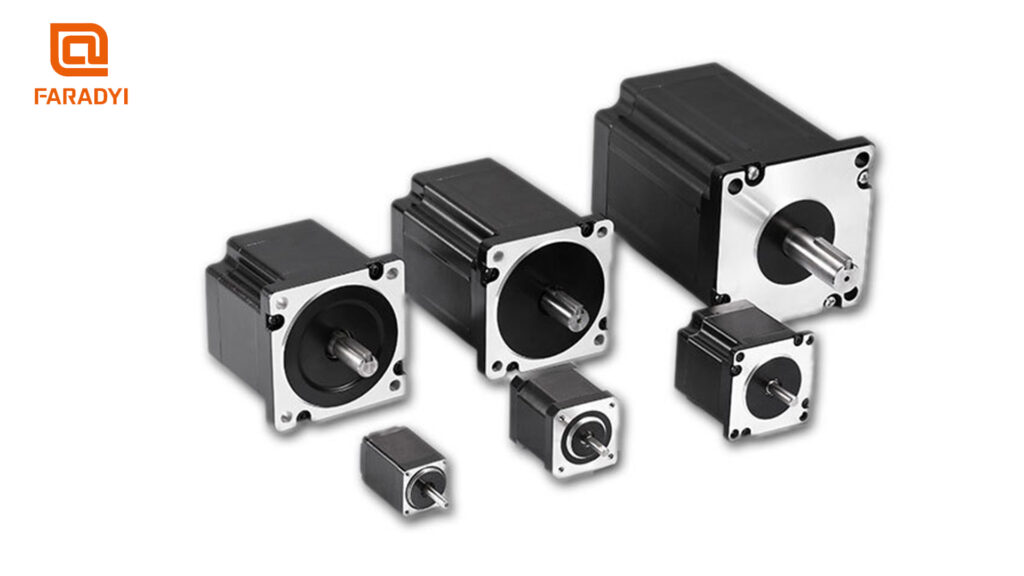
Learn how the stepper motor use environment impacts your selection. Discover how ambient temperature, humidity, and dust dictate insulation classes and motor lifespan.
Brushless DC Motor Square Wave Drive vs. Sine Wave
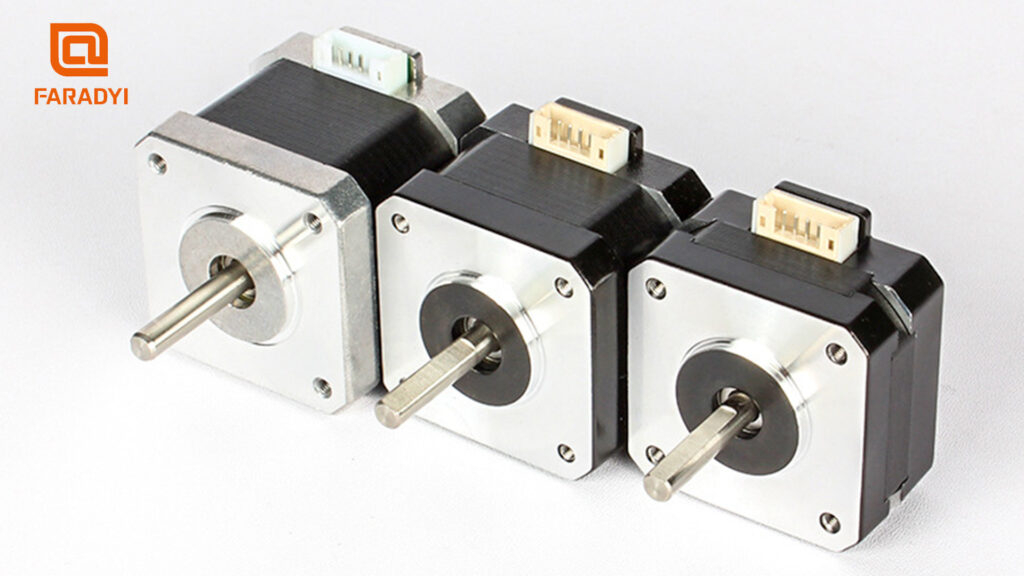
Choosing a drive system? Learn why a Brushless DC motor square wave drive offers lower costs and higher torque compared to sine wave alternatives for your automation.
ブラシレス DC モーター (BLDC) の利点
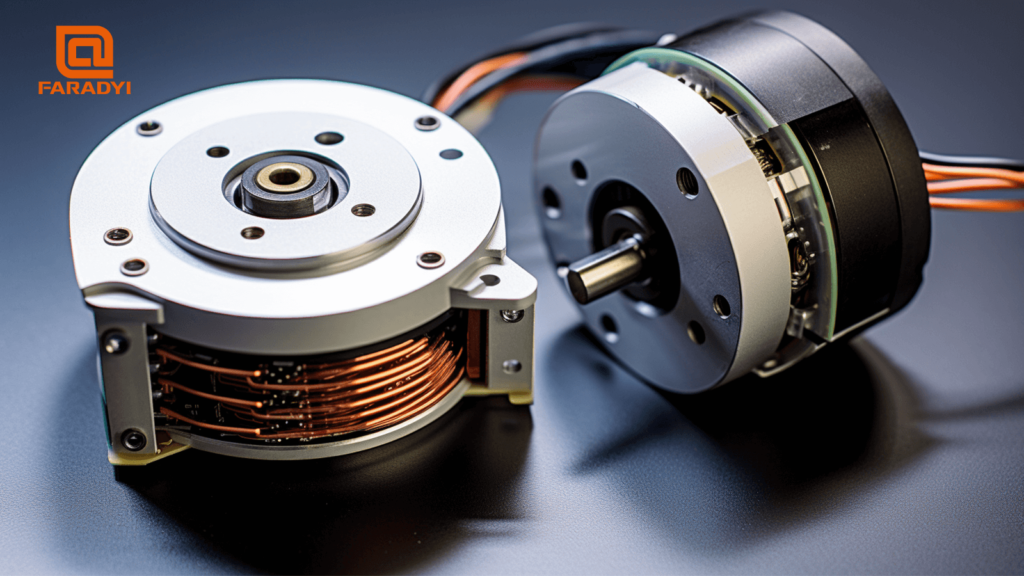
ブラシレス DC モーター (BLDC) は、従来の AC モーターや DC モーターに比べて、整流子、ブラシ、スリップ リングがないため、構造がシンプルで、動作の信頼性が高く、メンテナンスが容易です。
Understanding BLDC Motor Torque Ripple: Causes & Solutions
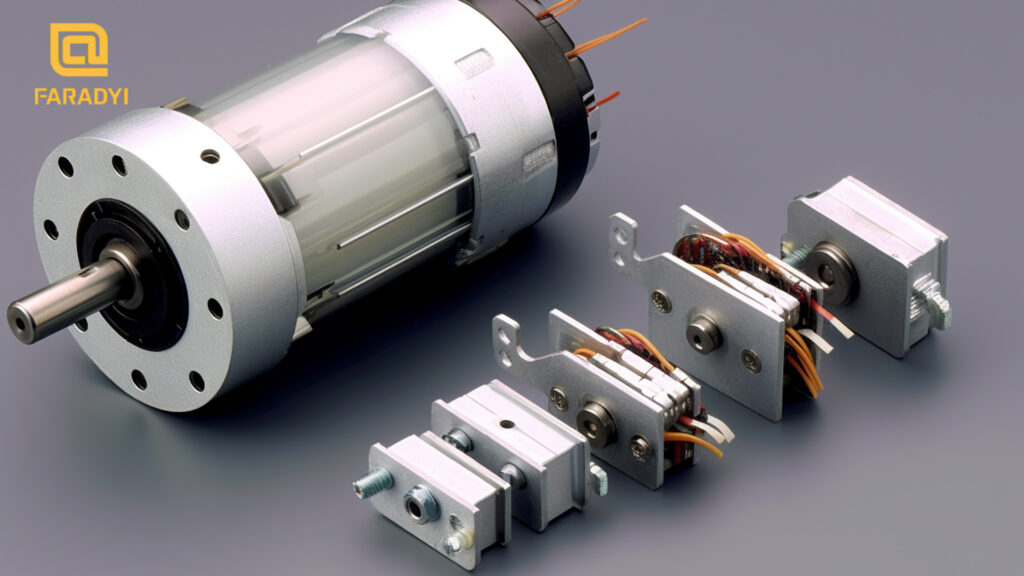
What causes BLDC motor torque ripple? Discover the main factors behind torque pulsation, its impact on motor vibration, and effective engineering solutions like FOC.
Comprehensive Guide to Brushless DC Motor Control Circuits
Discover how brushless DC motor control circuits work. Learn about rotor position decoding, PWM speed control, and variable structure control for BLDC motors.
複写機におけるステッピングモーターの応用
Discover the essential application of stepper motors in photocopiers. Learn why scanners, lenses, and paper feeders rely on high-precision stepper technology.
Best CAD Software for Brushless DC Motors | BLDC Design Tools & Workflow
Explore the top CAD software for brushless DC motors, including MotorSolve, SPEED, and Motor‑CAD. Learn workflows, FEA simulation, and BLDC design optimization.
ブラシレスDCモーターの設計技術要件とプロセス
ブラシレス DC モーターの設計技術要件と一般的な設計プロセス。ブラシレス DC モーターの設計や技術サポートの詳細については、お気軽にお問い合わせください。
ブラシレスDCモーターのボディ構造の選択方法
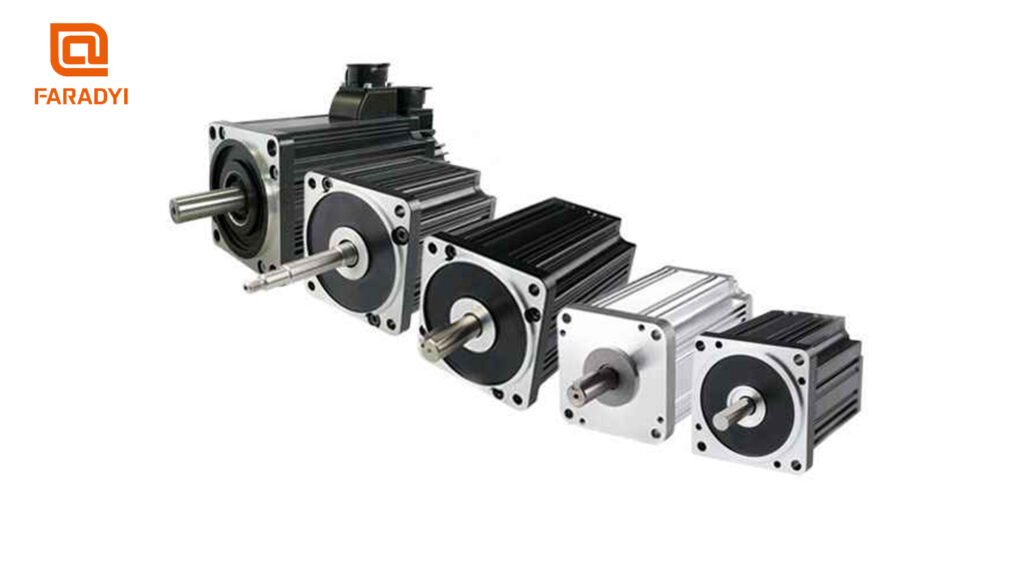
ブラシレス DC モーターのボディ構造の選択は、特定のアプリケーションのニーズとパフォーマンス要件を総合的に考慮して行う必要があります。適切な構造を選択すると、設計要件が最大限に満たされ、モーターの効率が向上し、信頼性が高まります。
DCサーボモータとACサーボモータの特性と機能の違い
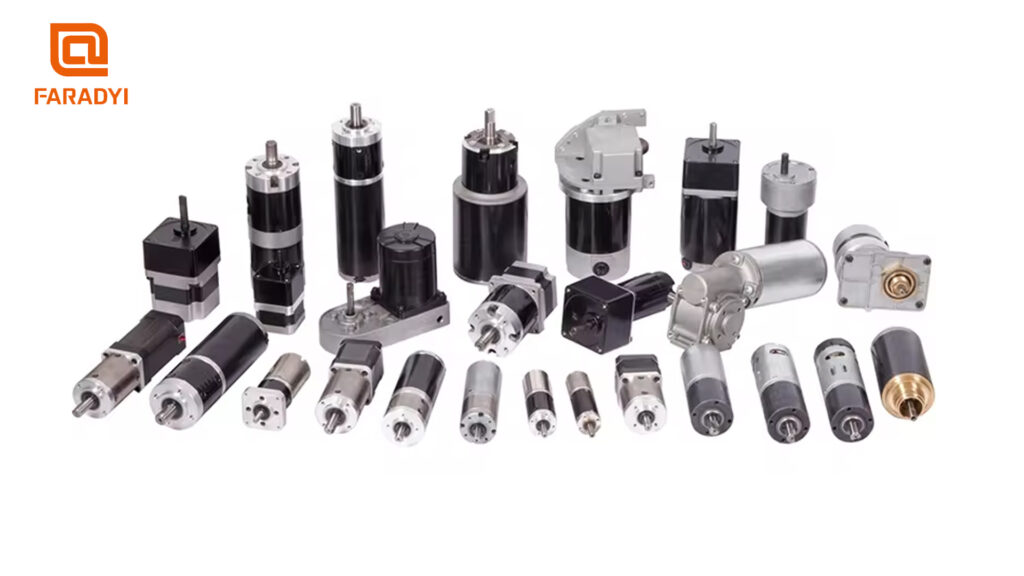
DC サーボ モーターと AC サーボ モーターの特性と機能の違いは、それぞれの長所と短所を反映しています。AC サーボ モーターは、柔軟な特性と幅広い用途が求められる用途に適していますが、DC サーボ モーターは、正確な速度制御、スムーズな動作、効率性が特徴です。技術の進歩に伴い、両方のタイプのモーターはさらなる改善が期待され、より効率的で信頼性の高いモーター システムにつながります。
ブラシレスモーターの起動と使用方法
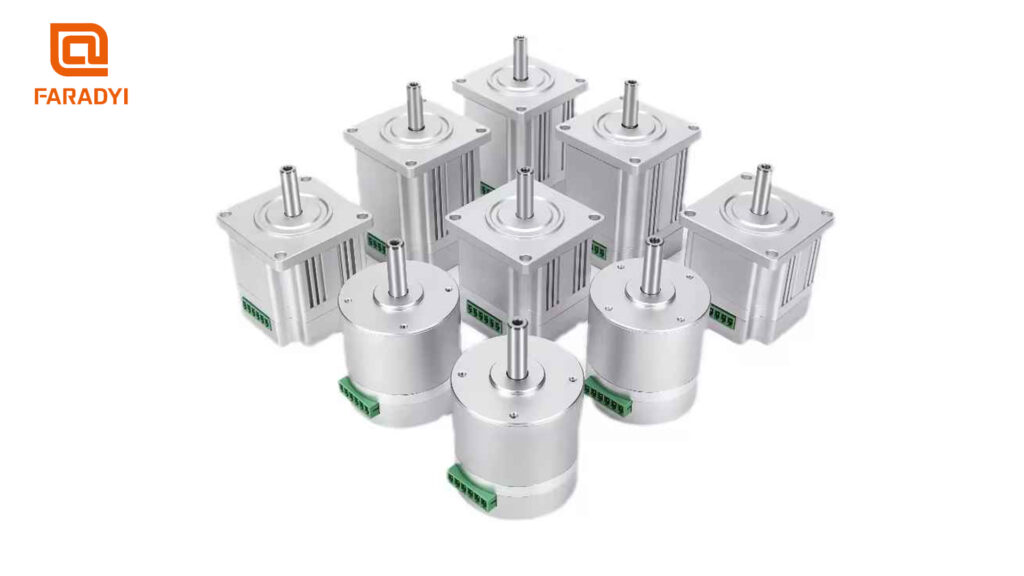
市販されているブラシレス モーターのほとんどは、位置を感知するためにホール センサーを使用し、通常の動作では正弦波コントローラーによって制御されます。
ステッピングモーターの低速運転時の振動と騒音の解析と解決
ステッピング モーターは、低速で動作しているときにジッターやノイズが発生する場合があります。解決策としては、サブディビジョン ドライバーの使用、設置環境の調整、ステップ角度の変更、サーボ モーターの検討などがあります。